
Two Drone Data Streams With Different Connectivity Needs Drone-in-a-box connectivity splits into two kinds of data that share almost nothing. Telemetry from the autopilot (position, attitude, battery, radio status) runs at a few kilobytes per second. Telemetry goes stale within seconds and needs a live cellular connection during the flight. Imagery from the camera runs to gigabytes per flight, often … Read More
Robot Teleoperation Latency: Combining Networks Adds a Hop That Pays Off During Handovers
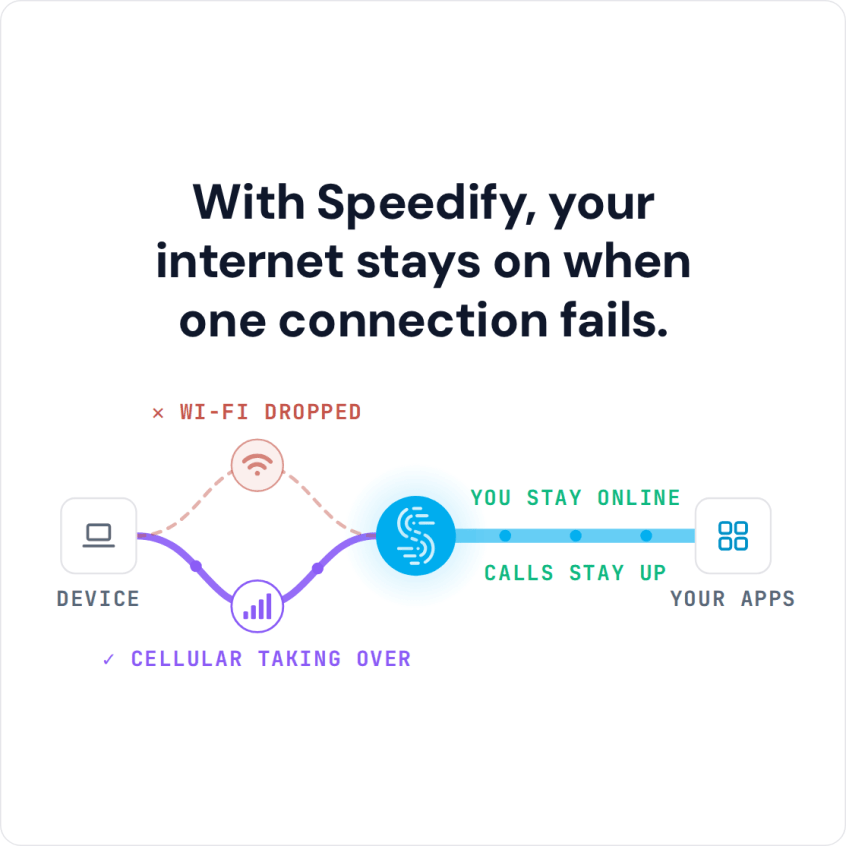
Where Delivery Robot Teleoperation Latency Comes From Robot teleoperation latency on a stable internet connection comes mostly from the camera and the video pipeline, not the network. Transitive Robotics measured about 170 ms glass to glass over remote WebRTC. About 100 ms of the total sat in the camera and the USB bus. On cellular, the bigger problem is handovers … Read More
- Page 2 of 2
- 1
- 2